Projects
02SO-101 Robot Arm with ROS 2 and MoveIt 2
Custom ros2_control hardware plugin for six Feetech bus servos, so a motion planned in MoveIt 2 drives the real arm. Includes joint calibration and a real/mock launch setup.
Six-Wheel Mars Rover, from Arduino to ROS 2
Rocker-bogie rover with 10 Dynamixel servos. Ackermann steering and RC control on an OpenCR board first, then a ROS 2 controller with micro-ROS, wheel odometry and 2D mapping.
Vacuum Robot Model in Simscape (Master's Thesis)
Parameterized multibody model of a differential-drive vacuum robot with contact and friction modelling. It matches the real robot's 19 mm obstacle limit and follows waypoints via Stateflow.
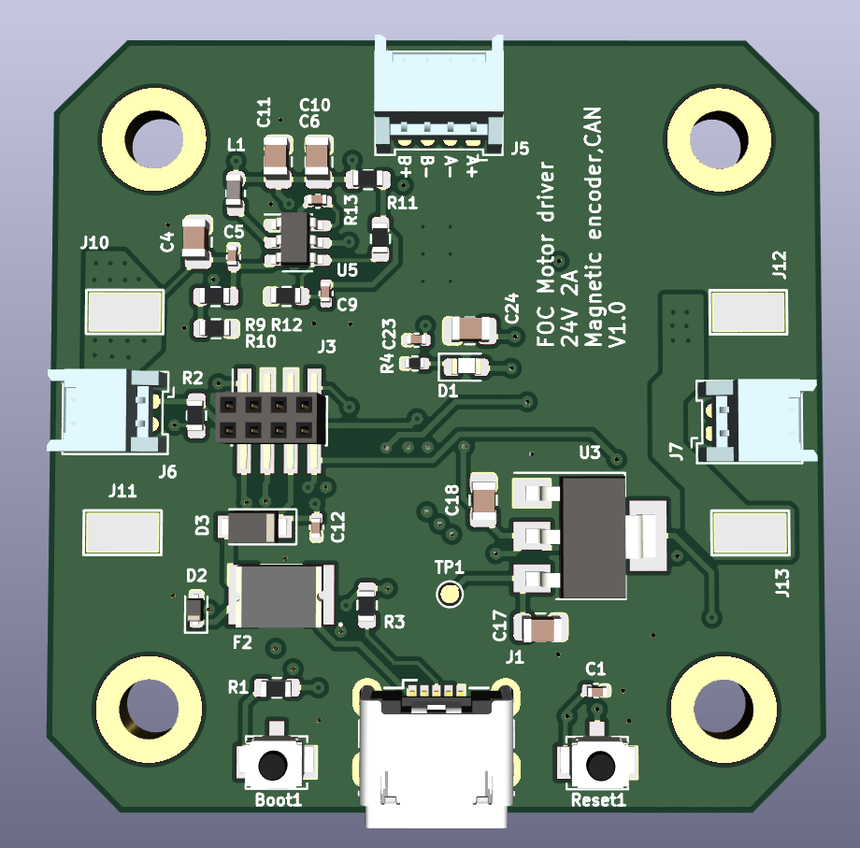
FOC NEMA17 Stepper Motor Driver
Custom four-layer driver board with STM32F103 control, DRV8844 H-bridge, magnetic encoder feedback, and CAN bus interface. Browse the live schematic and PCB below.
Furuta Pendulum
Furuta (rotary inverted) pendulum, modelled in Onshape and Simscape Multibody and built on hardware. A NEMA17 stepper on an STM32 Nucleo with an IHM01A1 driver turns the arm, and an AS5600 encoder reads the pendulum angle.
Two-Wheel Balancing Robot
Self-balancing robot. An ESP32 reads the tilt from a BMI160 IMU and drives two DC motors through a TB6612FNG H-bridge, powered from a 7.6 V LiPo via an LM2596 buck converter.
Delta Robot
Delta robot with SG90 servos and 3D printed parts, modelled in Onshape, with an animation of the three arms moving the plate.
Cylinder Assembly
Flange-mounted cylinder assembly modelled in Onshape, with an animated piston and rod stroke shown through a transparent barrel.